Your browser can’t render the 3D transitions, so the slides are shown as a simple scroll.

Before we start

What’s one thing you would expect from your own personal robot?

Hold that answer in your head.
Here’s mine.

For me

The Breakfast Machineby Simone Giertz, on YouTube

Hand it the keys to everything I own — and trust it never to break a thing.

Now imagineit’s not milk.

  • A dinner rush, packed wrong.
  • A heavy tool, dropped on site.
  • A jobsite nobody’s watching.
Tuesday, 4:55 AM
4:55
▶Robot11:48 PMOvernight job started.
◉Robot Cam1:26 AMYou opened the live feed.
◉Robot Cam3:12 AMYou opened the live feed. Again.
!Robot4:55 AMTask failed (error 0x3F).

Robot models got a lot smarter in just a few weeks.

Generalist ✓@GeneralistAI𝕏

Introducing GEN-1.5, a one-shot learner. It can learn new tasks in a few seconds.

Aug 19, 2026 · 3.4M views

Skild AI ✓@SkildAI𝕏

Introducing S1, our new foundation model that learns from one example.

Aug 25, 2026 · 3.5M views

Jay Chooi ✓@chooi_jeq𝕏

GPT-6 Astra scored 95% on a robot control task, up from Fable 5.1’s 40%.
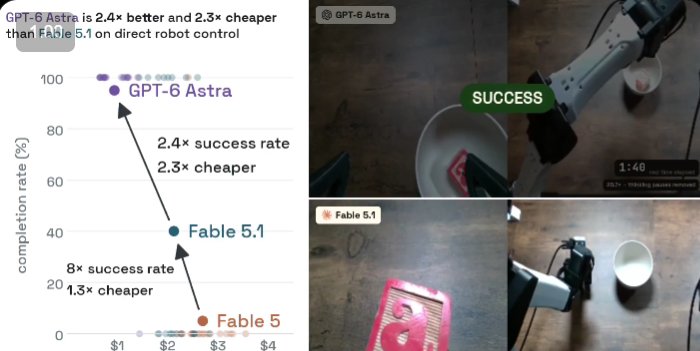
Chart: GPT-6 Astra at 95% completion rate versus Fable 5.1 at 40% on direct robot control, with robot camera frames

Sep 4, 2026 · 1.9M views

thijs ✓@cdngdev𝕏

i gave astra a robot, a paint brush, and a camera then asked it to paint the golden gate bridge in real life!

What robots can do
Knowing when to trust them

Capability is sprinting. Trust is still tying its shoes.

So here’s my plan.

  1. Catch it before it breaks.safety layer
  2. Learn from every miss.failure-driven correction
  3. Say it in plain words.human-readable interface

A robot that fails safely, gets better from its failures, and tells a restaurant owner what happened, why, and what to do — even at 4:55 AM.
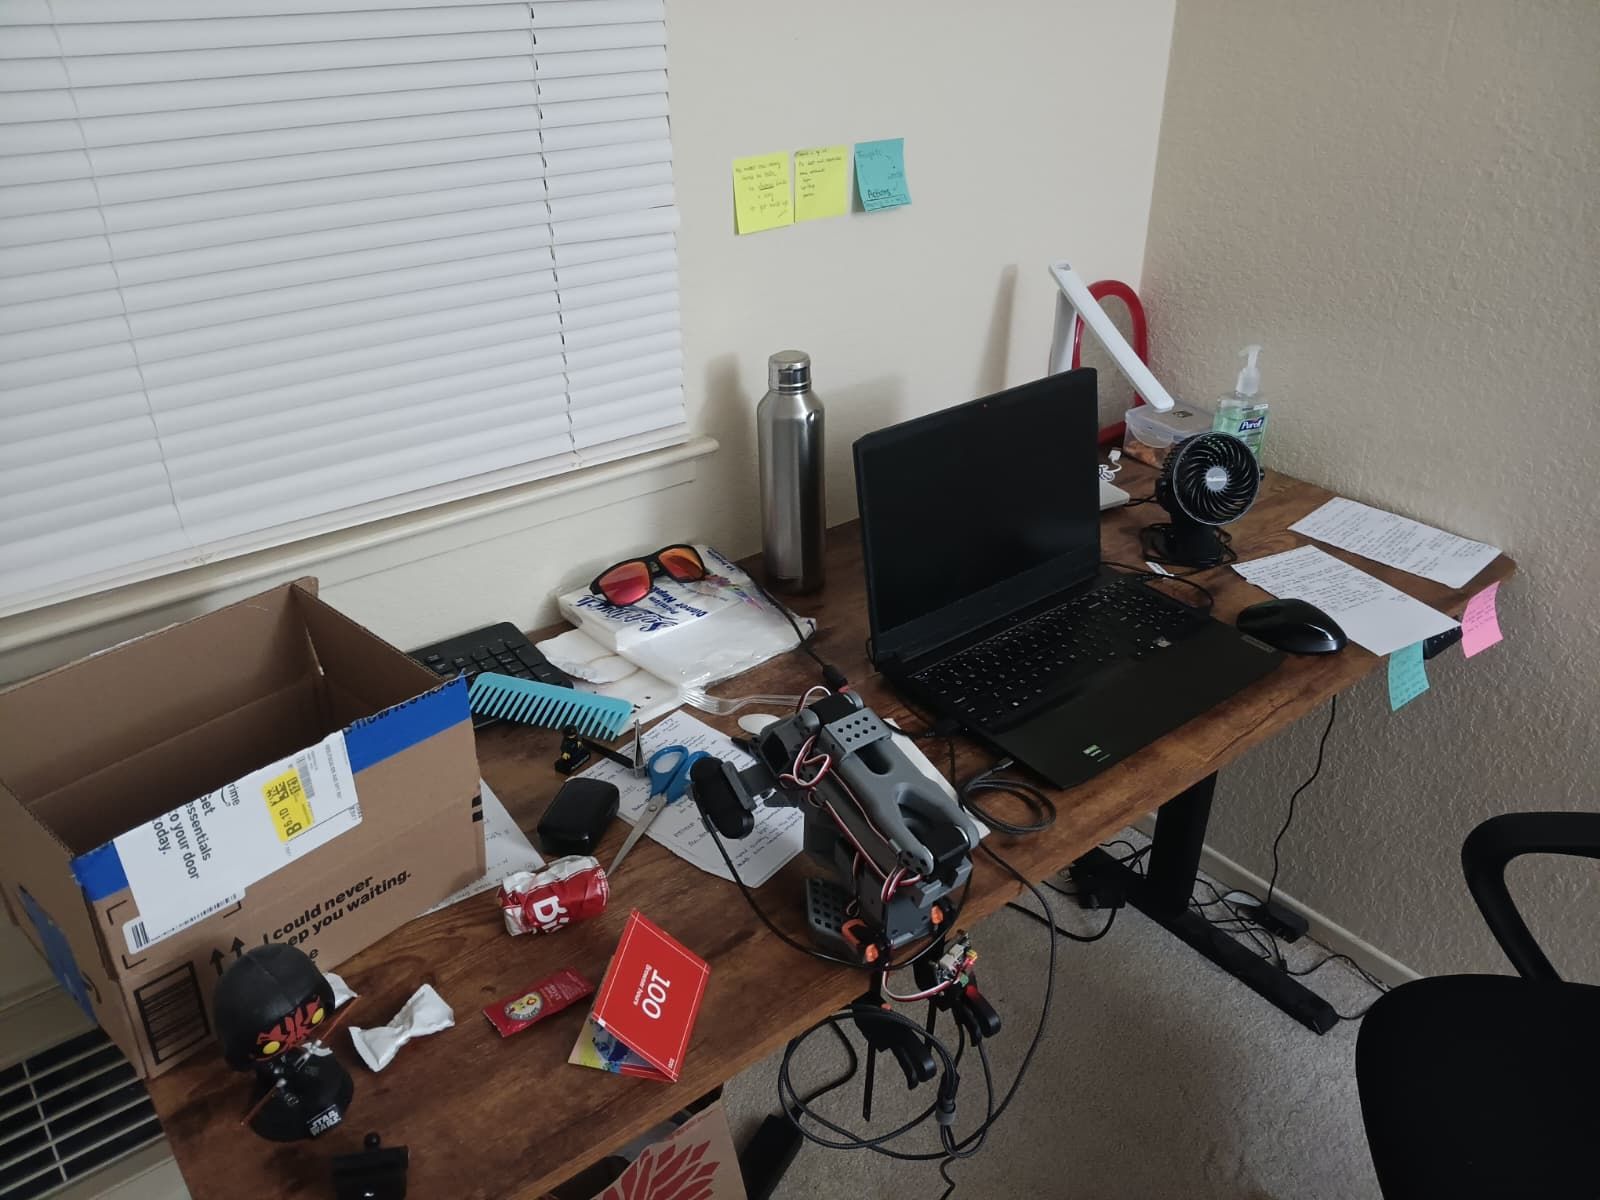
Hitesh's cluttered desk: an open box, a crushed can, scissors, a comb, snacks and papers around an SO-101 robot arm
my helper

Starting with the most tedious task I know.My desk.

Every day it ends up like this. Every day I clean it up.
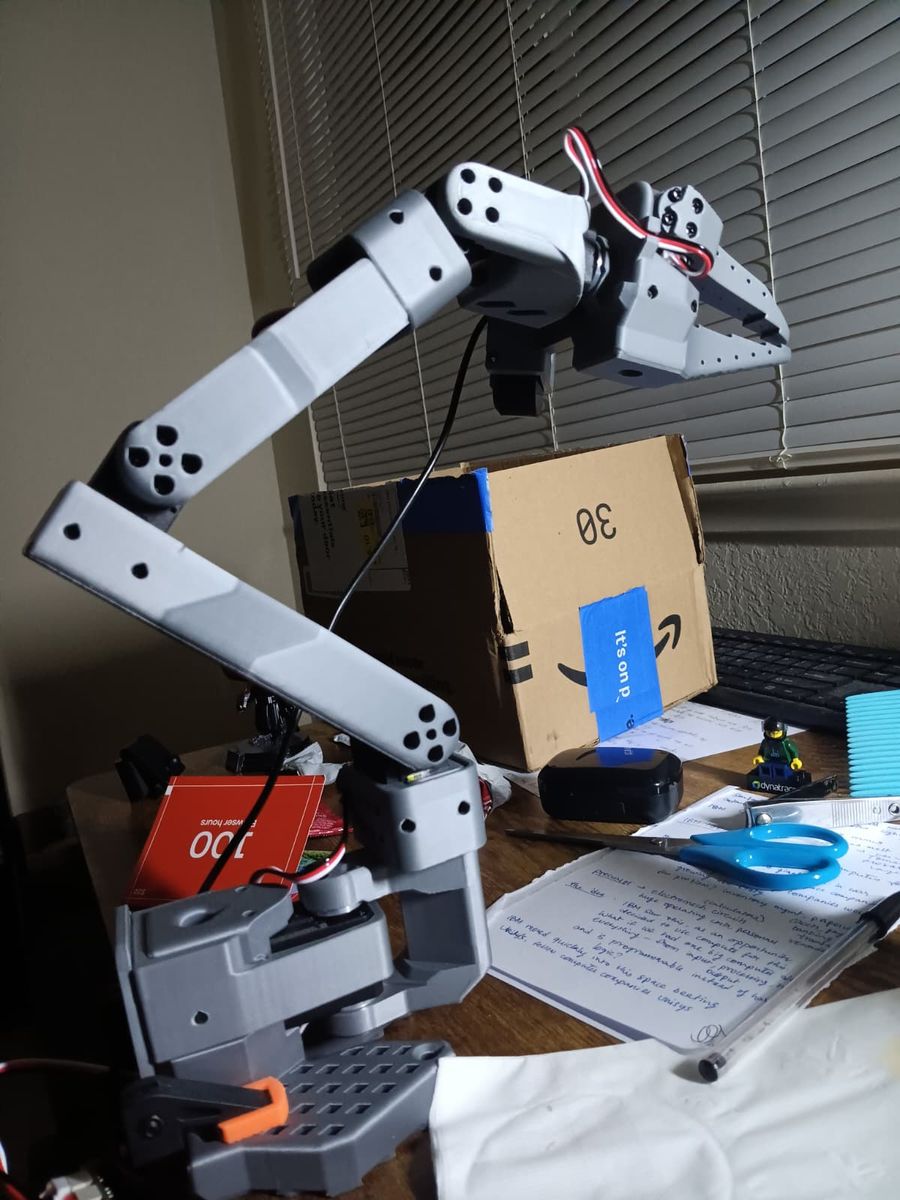
Close-up of the SO-101 robot arm on the desk

Meet Solo,
my SO-101 arm.

  • 6 servosfive joints and a gripper
  • One cameramounted on the wrist
  • No sense of touchit can’t feel how hard it’s gripping
  • Runs SmolVLAtrained on my own demonstrations

Cheap and imperfect — so it fails often enough to learn from.

What failure looks like.

FAILUREwrist cam

Failed grasp: wrong orientation

Right object, wrong angle. The gripper comes in rotated, and the grasp fails.

FAILUREwrist cam

Lost the table

The wrist rolls. Its camera sees wall and ceiling — the table is gone.

Every one of these is a signal. Right now, they just get thrown away.

How I catch it, in one picture.

Catch it before it breaks
Say it in plain words
THE ROBOT

Does the task

SmolVLA drives the arm from its wrist camera.

“Pick up the can.”
inspired by FIPER, Sentinel1 · WATCH

Is this normal?

A cheap check on every frame.

Gripper closed. Nothing in it.
inspired by safety filters2 · STOP

Freeze first

Pause before anything gets broken.

Arm paused. Holding still.
inspired by AHA, REFLECT3 · EXPLAIN

Say what went wrong

A vision-language model puts it in words.

“I missed the can. It’s further left than I reached.”
4 · ASK

You decide

Help, skip, or let it carry on alone.

RetryNudge itSkip
5 · LEARN

Learn from every miss

  1. Log itclip + what happened
  2. →
  3. Sort itinto failure types
  4. →
  5. Record moreof exactly that case
  6. →
  7. Retrainthe policy gets better
inspired by FailSafe

Most research builds one of these boxes. My work is the wiring — one loop, with a person in it, on a cheap arm.

Where I actually am

This is day one.

The plan is on paper. The arm is on my desk. I’ll build the rest in public — failures included.

→ de-clutterbot.vercel.app Robot did something dumb? Send me the clip.

Thank you.

scan to follow along
Turn your phone sideways for the full talk.
1 / 2